Remove box from gripper, pick up, localized
-
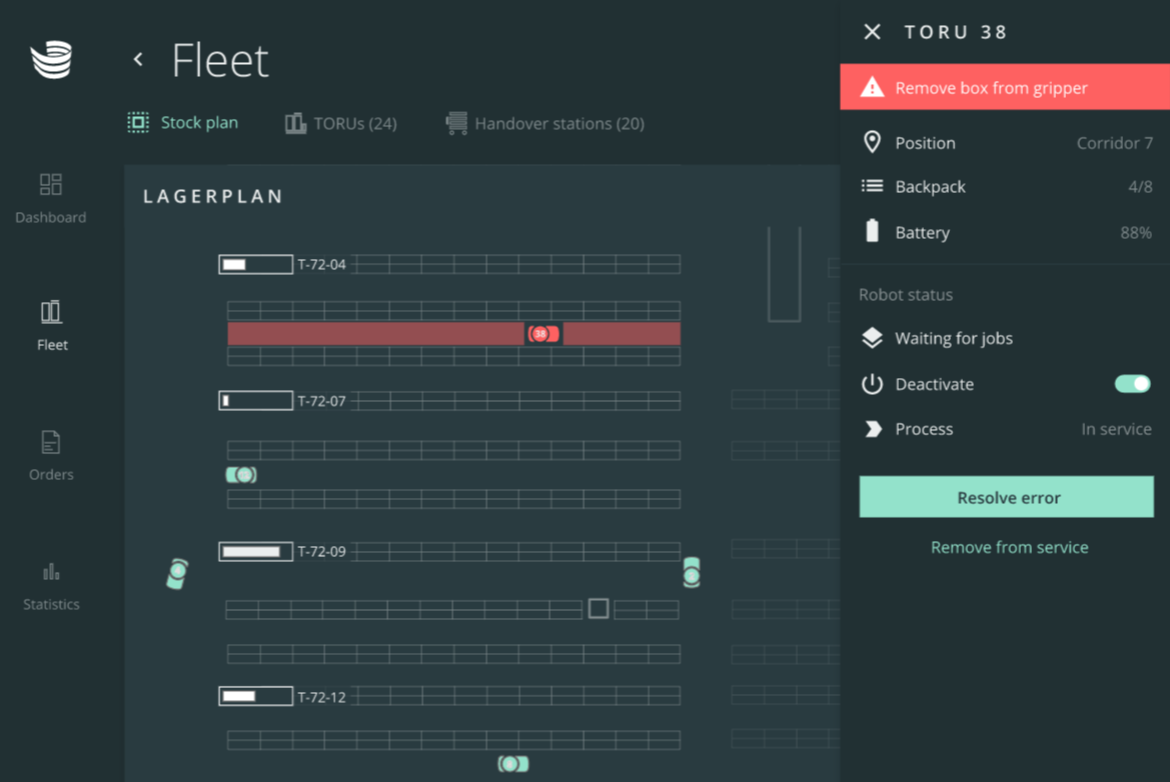
Navigate to the Fleet section and press the red robot icon. Then press the ‘Resolve error’ button.
-
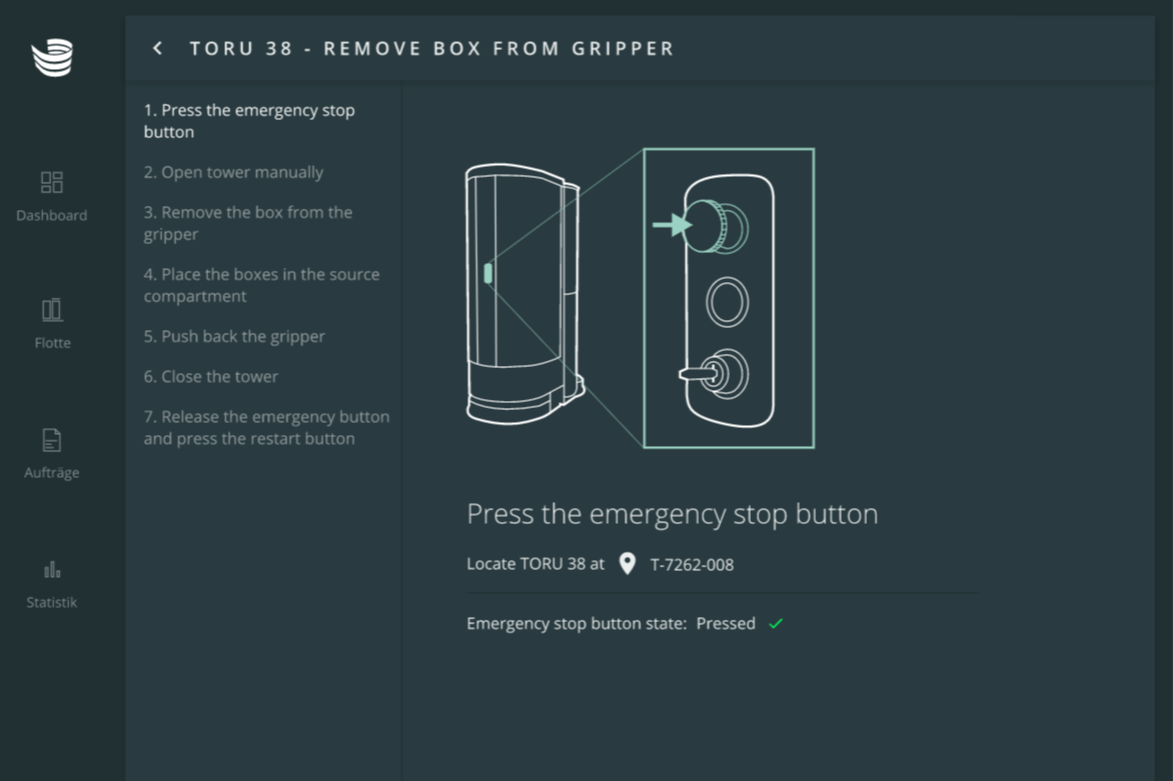
Proceed to the robot and press the emergency stop button. The emergency stop button state should change to “Pressed” in ARC. Then press ‘Next’.
-
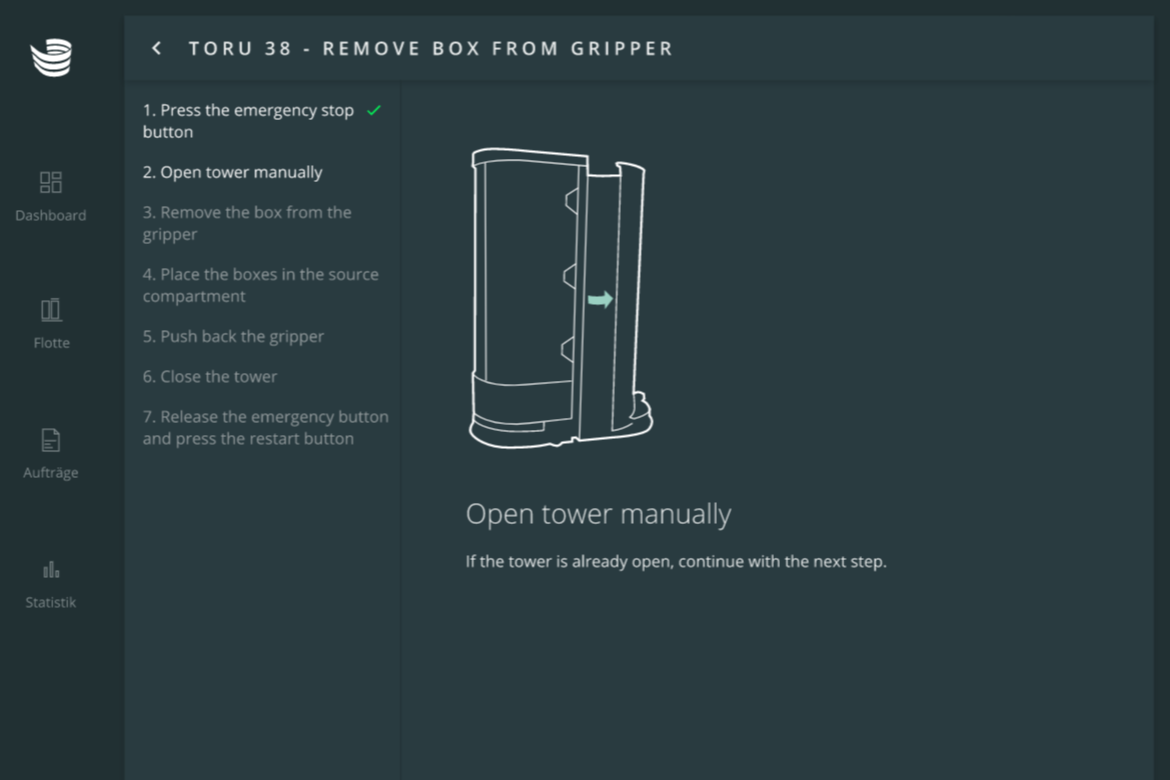
Manually open the tower of the robot by gently rotating it. Then press ‘Next’ in ARC.
-
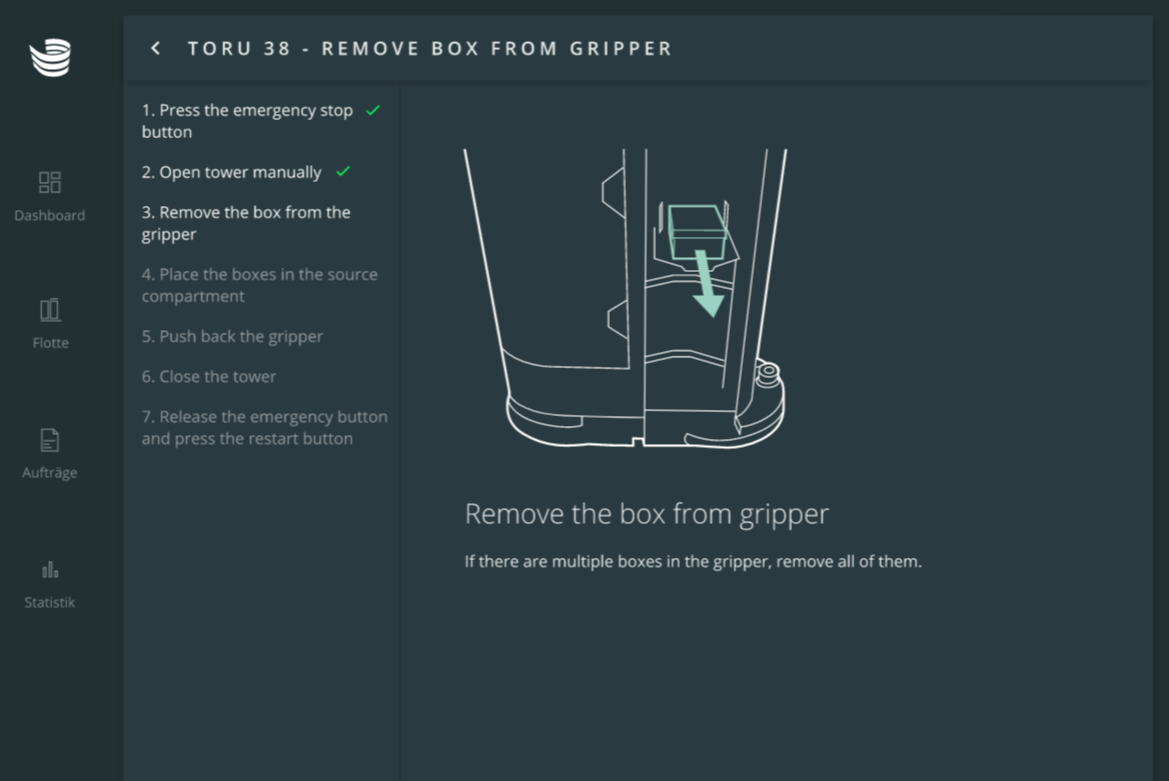
Remove all boxes from the gripper. Then press ‘Next’.
-
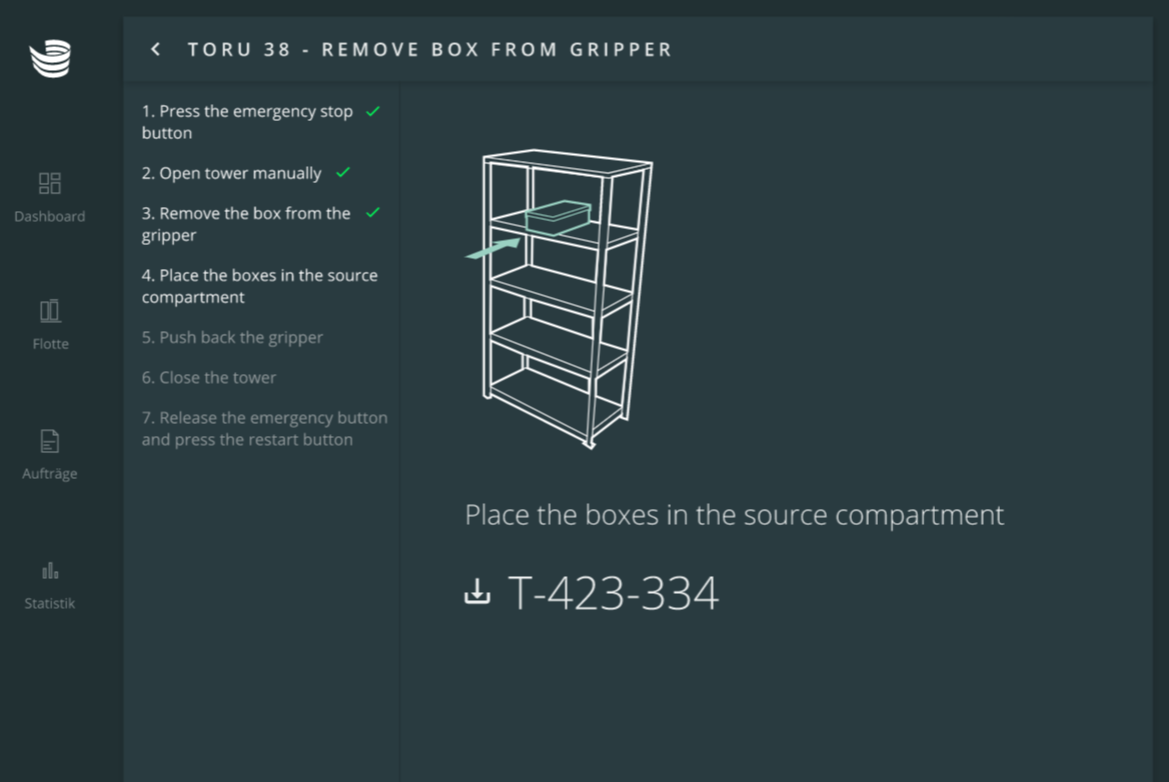
Place the boxes in the specified source compartment. Then press ‘Next’.
-
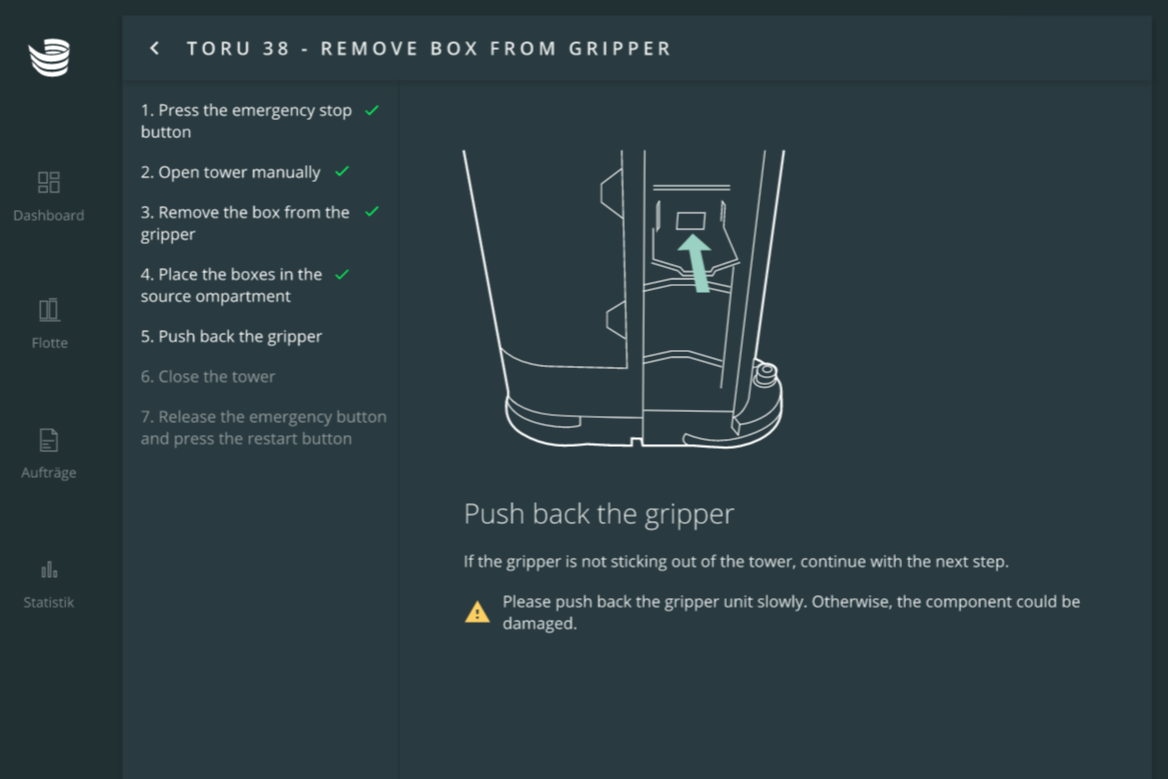
If the gripper is sticking out, gently push it back into the tower. Please make sure not to damage any components. Then press ‘Next’.
-
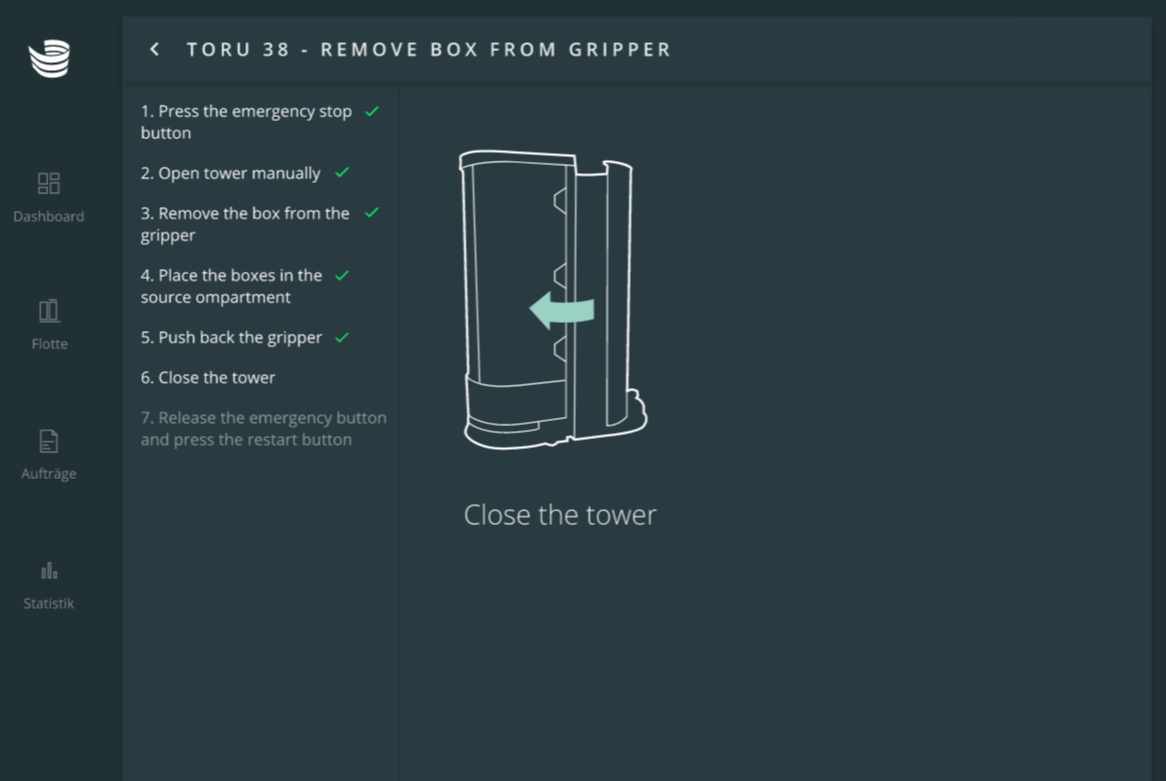
Close the tower and press ‘Next’.
-
Release the emergency button on the robot and press the restart button. Then press ‘Next’.
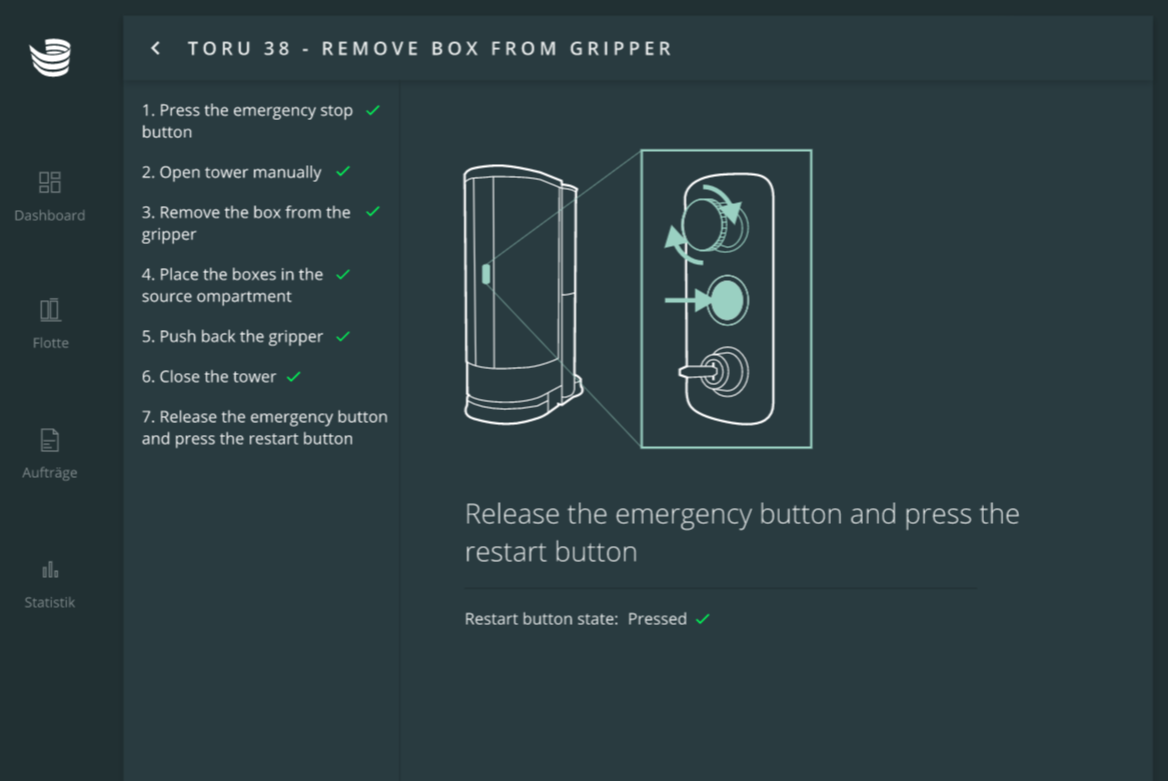
-
Press ‘Complete intervention’ and wait for the robot to restart. Verify there are no remaining errors.
Remove box from gripper, pick up, unlocalized
-
Navigate to the Fleet section and press the red robot icon. Then press the ‘Resolve error’ button.
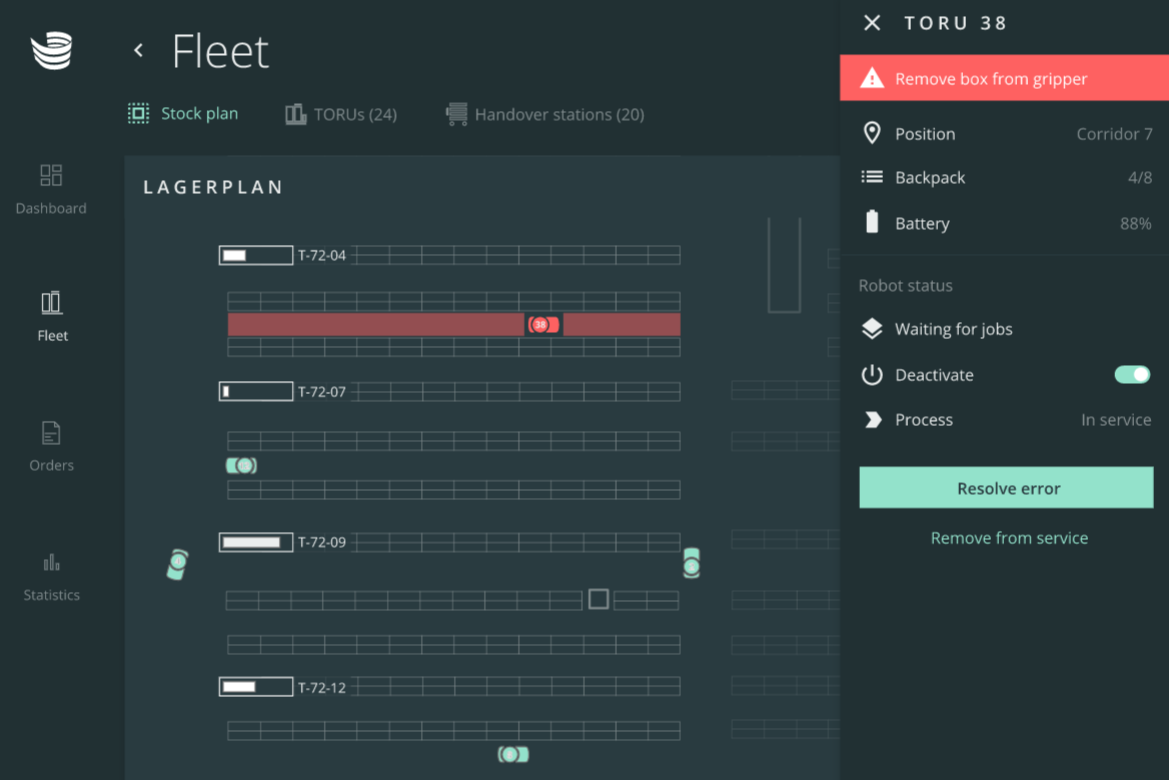
-
Proceed to the robot and press the emergency stop button. The emergency stop button state should change to “Pressed” in ARC. Then press ‘Next’.
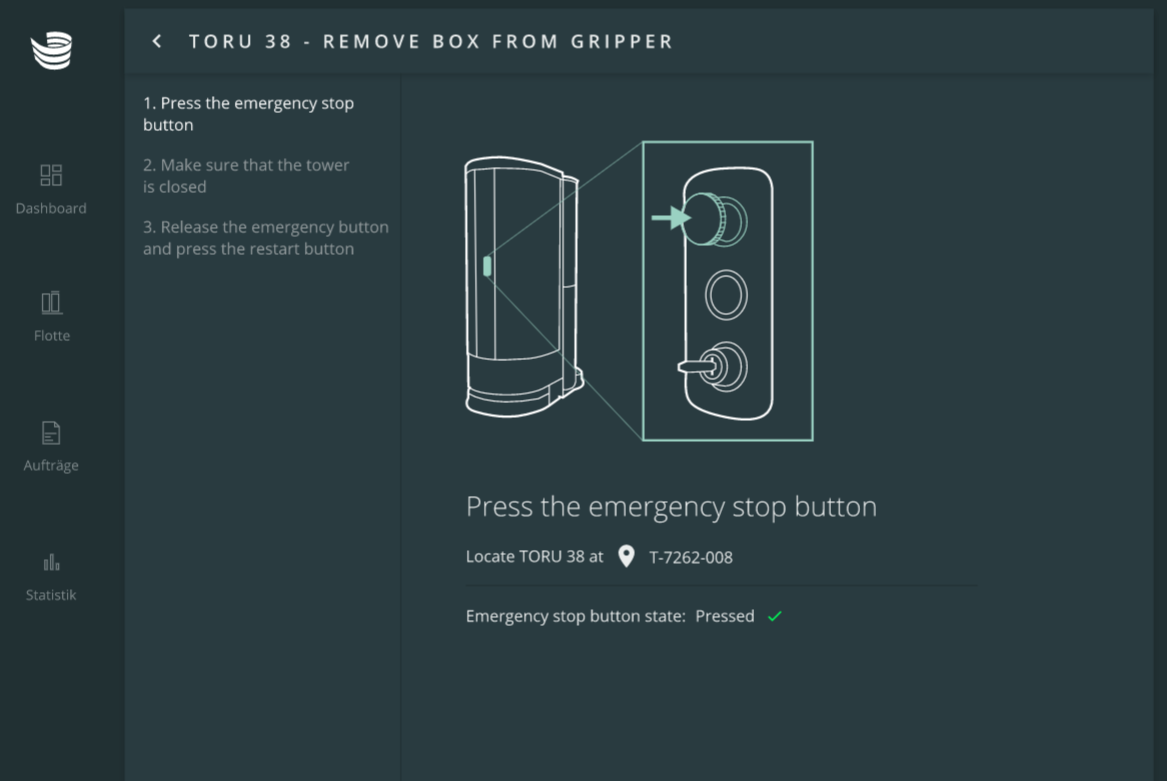
-
If the tower of the robot is open, close it manually. Then press ‘Next’.
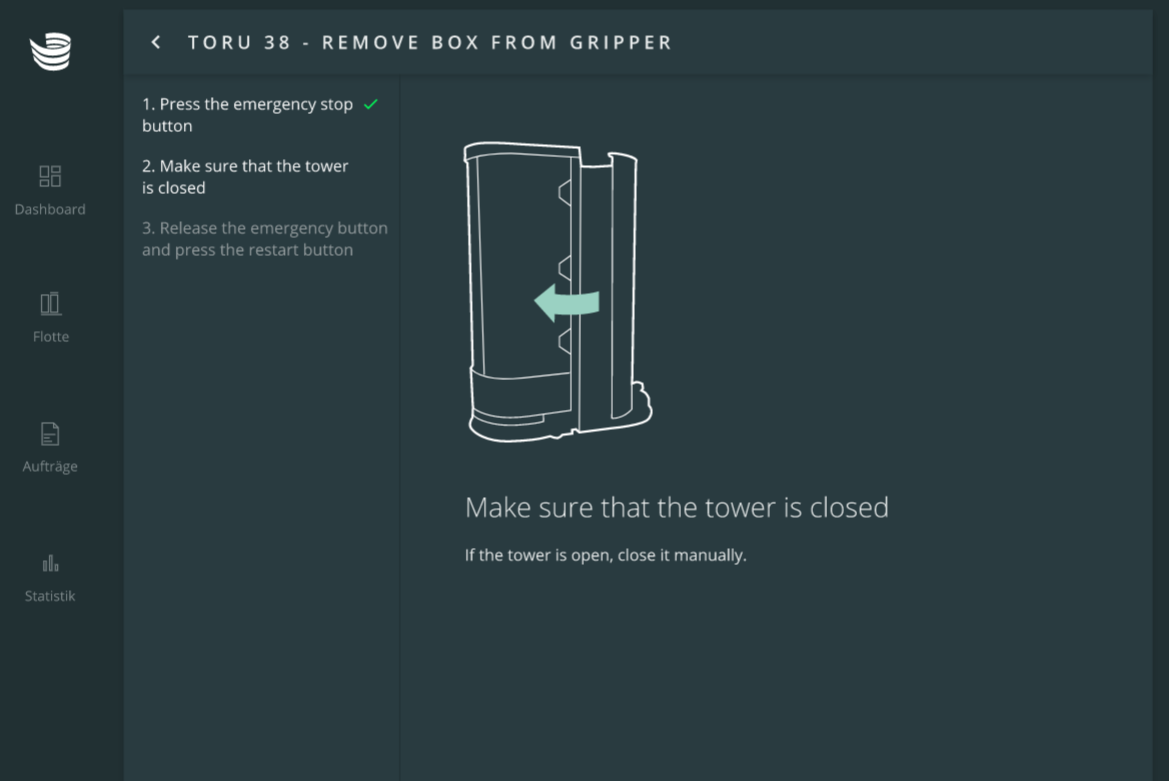
-
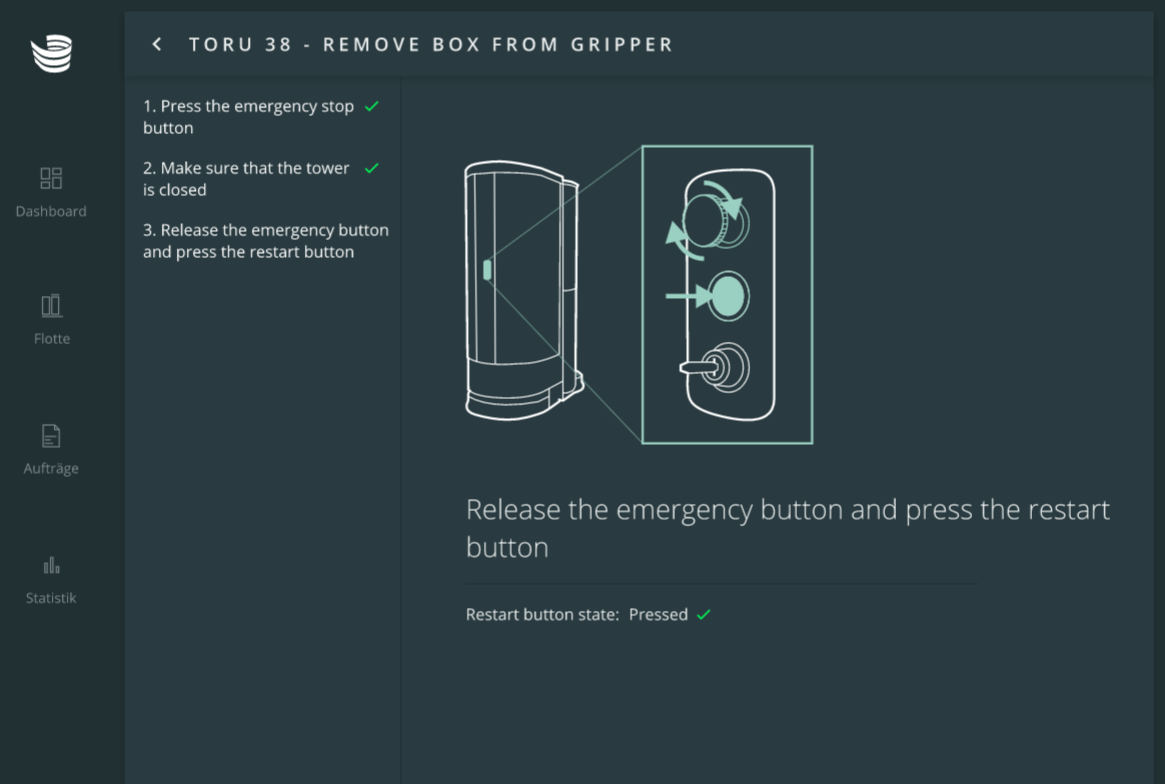
Release the emergency button and press the restart button on the robot. The restart button state should change to “Pressed” in ARC. Then press ‘Next’.
-
Press ‘Complete intervention’ and wait for the robot to restart. Verify there are no remaining errors.
Remove box from gripper, put down, localized
-
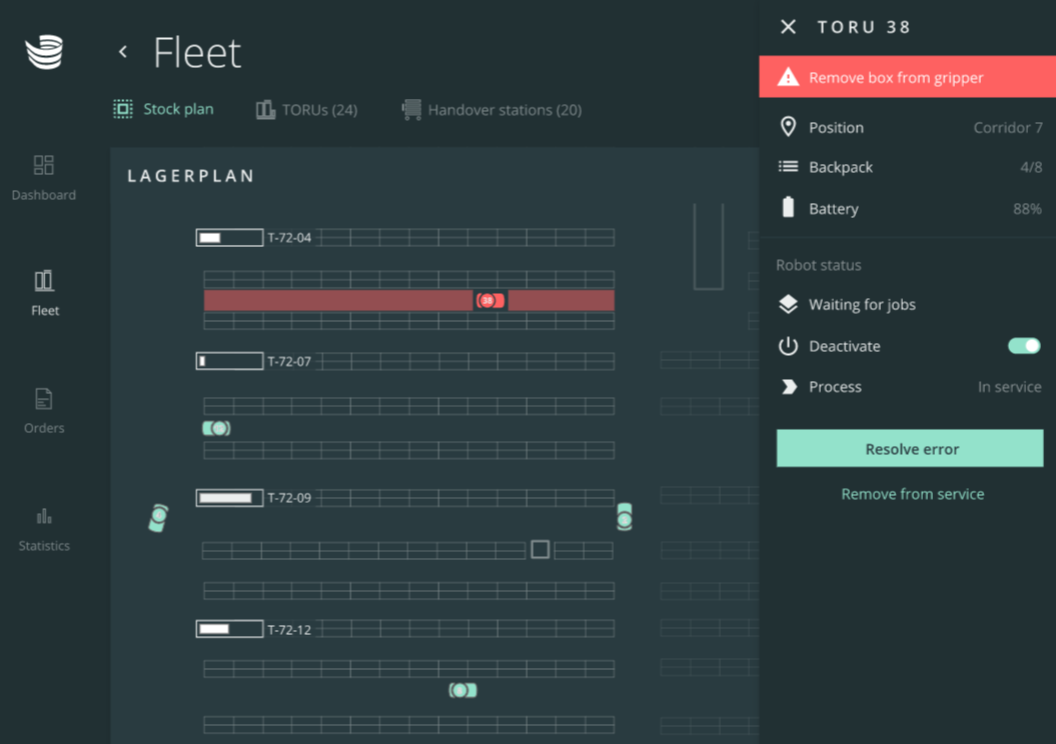
Navigate to the Fleet section and press the red robot icon. Then press the ‘Resolve error’ button.
-
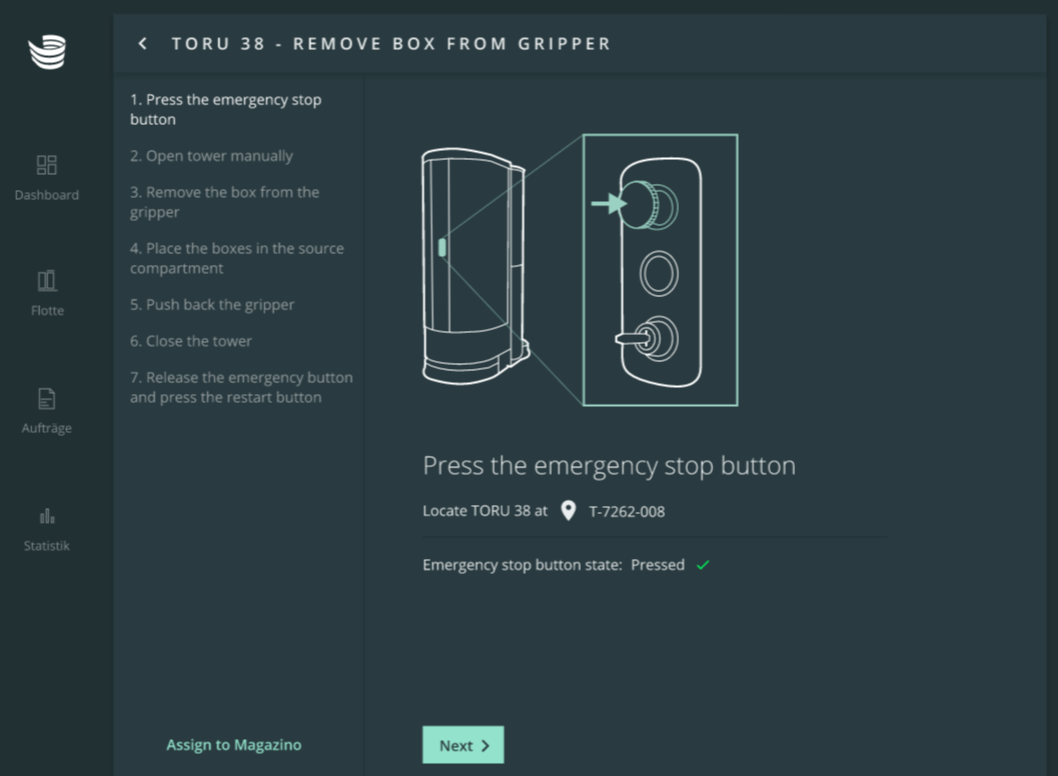
Proceed to the robot and press the emergency stop button. The emergency stop button state should change to “Pressed” in ARC. Then press ‘Next’.
-
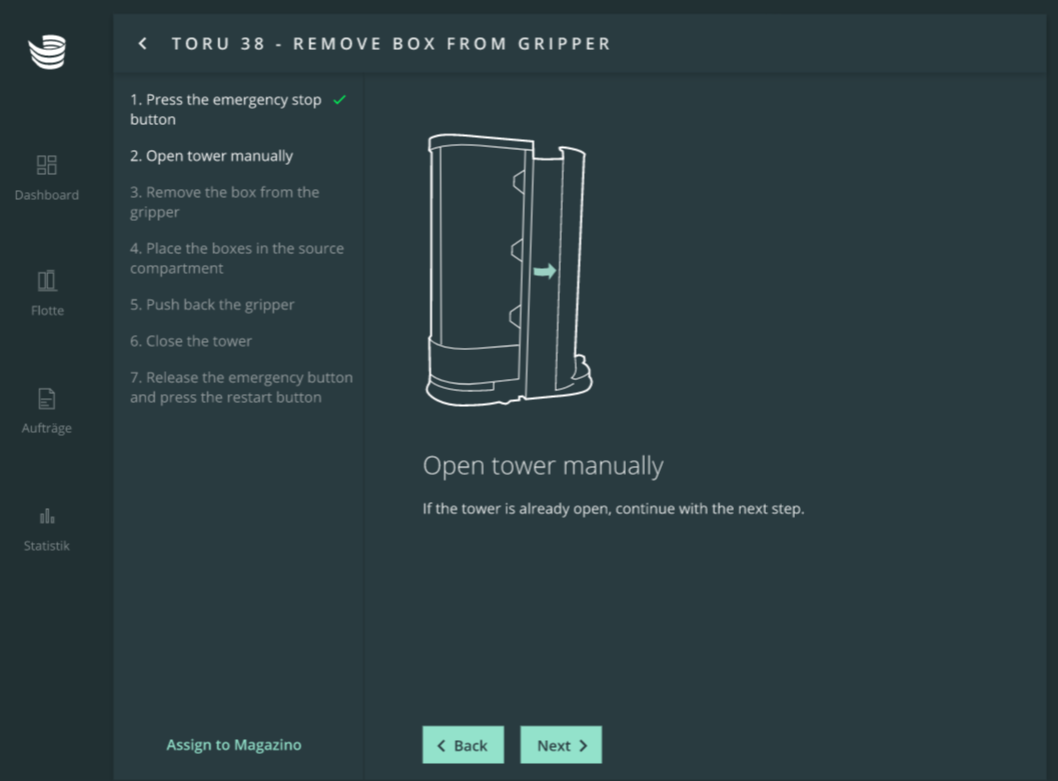
Open the tower by gently rotating it to the right. Then press ‘Next’.
-
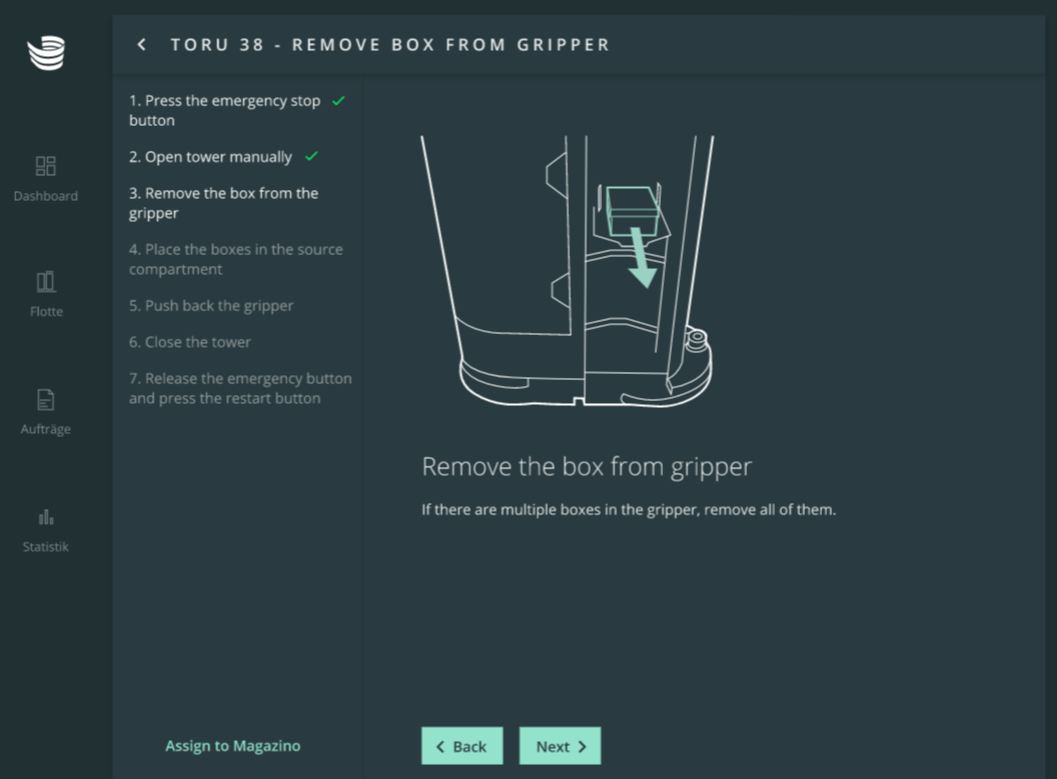
Remove all boxes from the gripper. Then press ‘Next’.
-
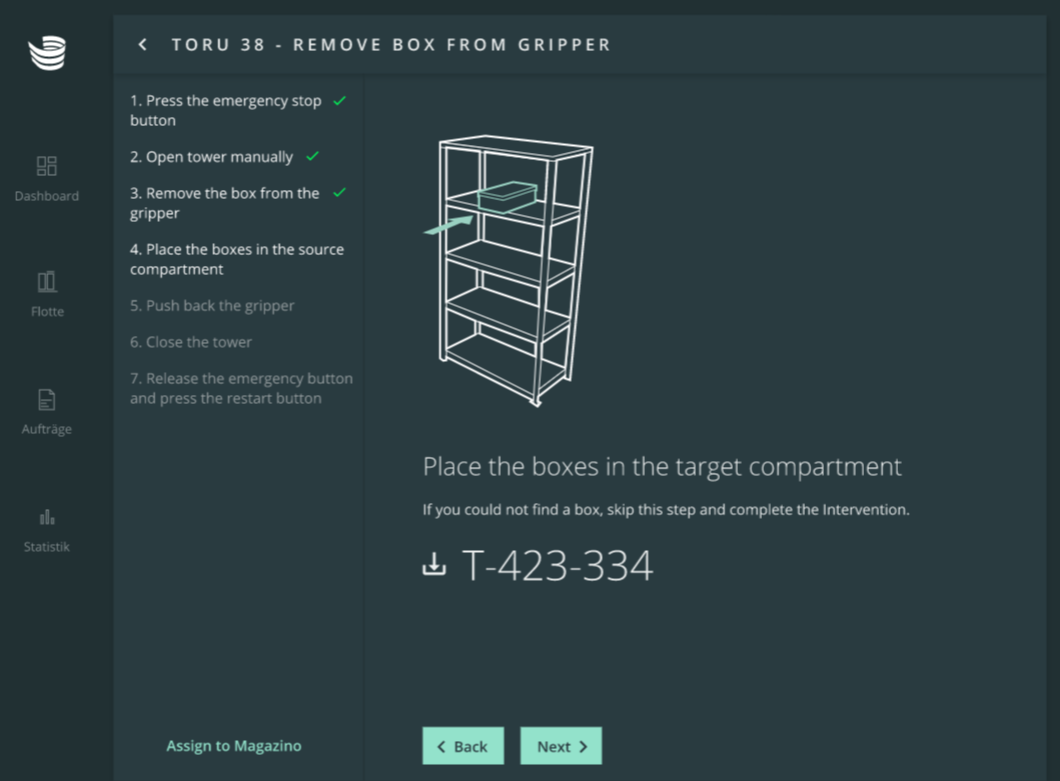
Place the boxes in the specified source compartment. Then press ‘Next’.
-
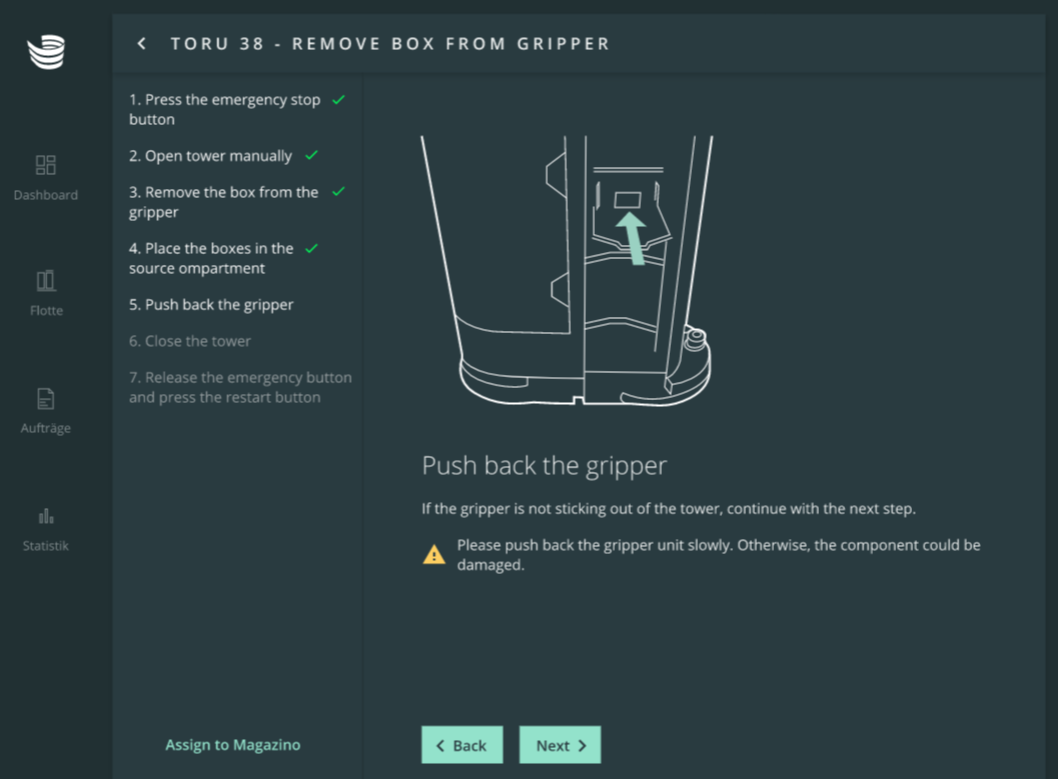
If the gripper is sticking out, gently push it back into the tower. Please make sure not to damage any components. Then press ‘Next’.
-
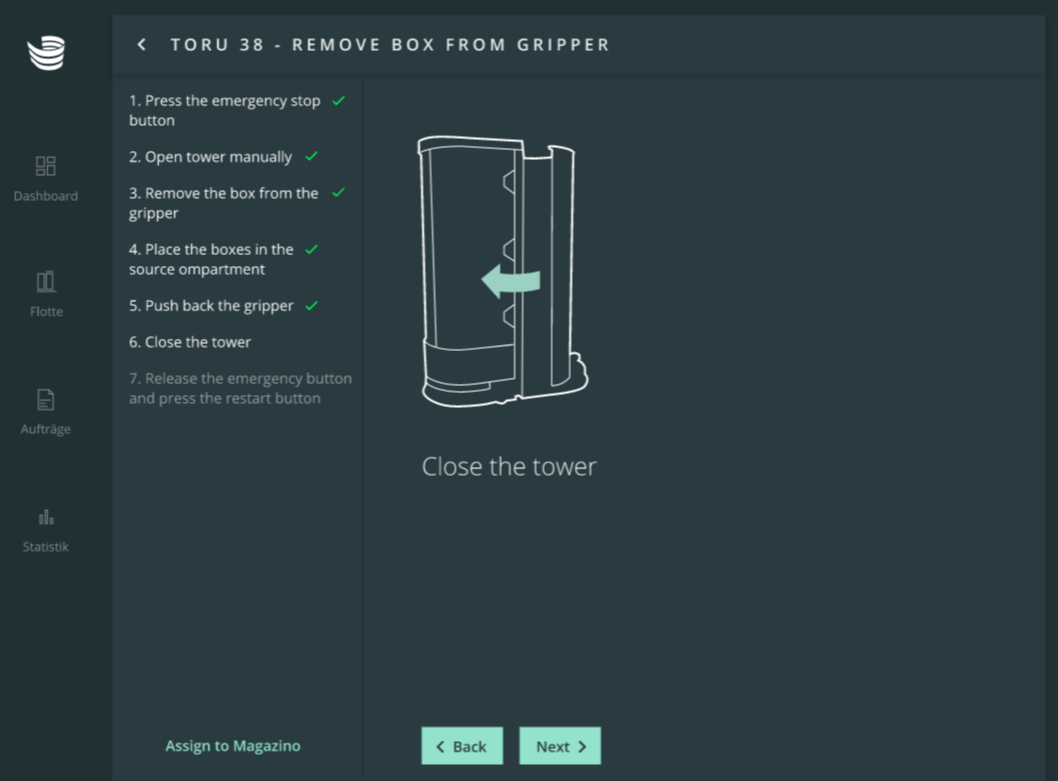
If the tower of the robot is open, close it manually. Then press ‘Next’.
-
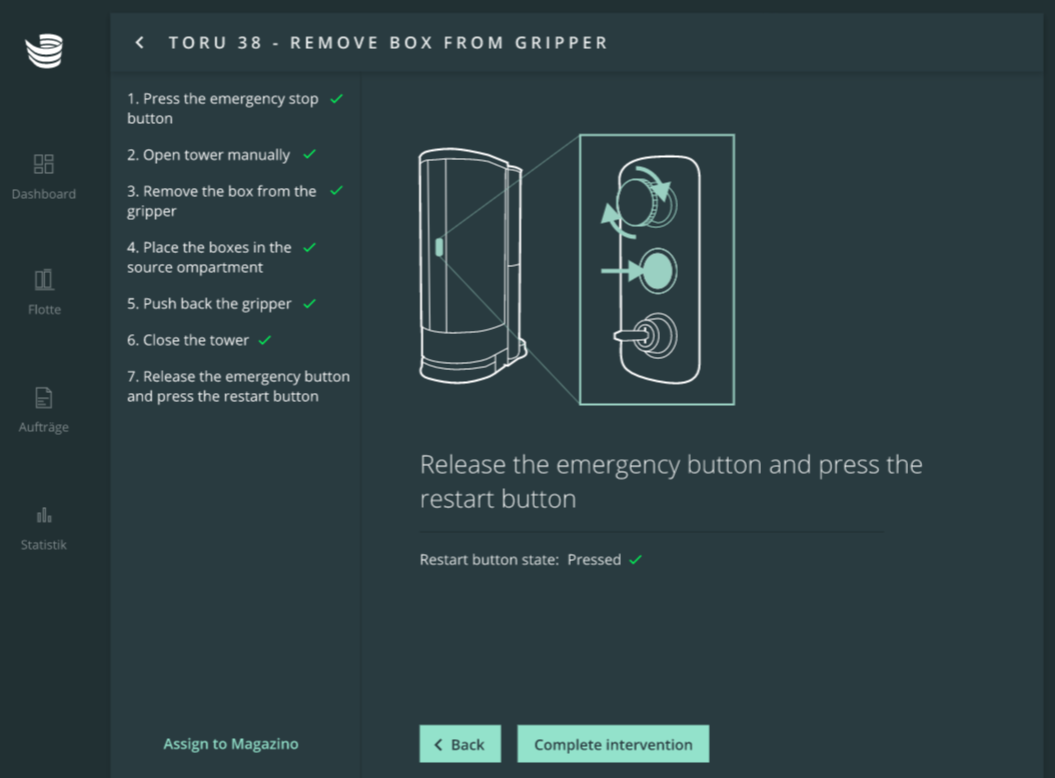
Release the emergency button and press the restart button on the robot. The restart button state should change to “Pressed” in ARC. Then press ‘Next’.
-
Press ‘Complete intervention’ and wait for the robot to restart. Verify there are no remaining errors.